FlowMoDE: Coarse-to-fine Flow Matching for Structure-aware Sim-to-Real Monocular Depth Estimation
Abstract
Monocular depth estimation is a fundamental capability for 3D spatial perception in robotic and intelligent systems. While data‑driven discriminative methods have achieved compelling performance for monocular depth estimation, generative approaches can reconstruct fine structural details with stronger generalization. However, most existing generative diffusion models suffer from low inference efficiency caused by multi‑step sampling, whereas single‑step diffusion models struggle to recover high‑fidelity depth maps. To mitigate these drawbacks, this paper presents FlowMoDE, a coarse‑to‑fine flow‑matching‑based framework for efficient, structure‑aware monocular depth estimation supporting sim‑to‑real and cross‑scene generalization. The core architecture first conducts coarse‑level decoding conditioned on diffused features extracted from a pre‑trained semantic encoder, and subsequently restores fine‑grained structural patterns via expanded decoding layers. Trained exclusively on a single synthetic indoor dataset, our proposed method outperforms prior methods across five real‑world indoor and outdoor datasets, yielding an average 14.1% reduction in relative error against state‑of‑the‑art works as well as 9.9% reduction in chamfer distance for point cloud reconstruction. We further validate the generalization capability of FlowMoDE on realistic robotic scenes, with qualitative comparisons against SOTA methods.
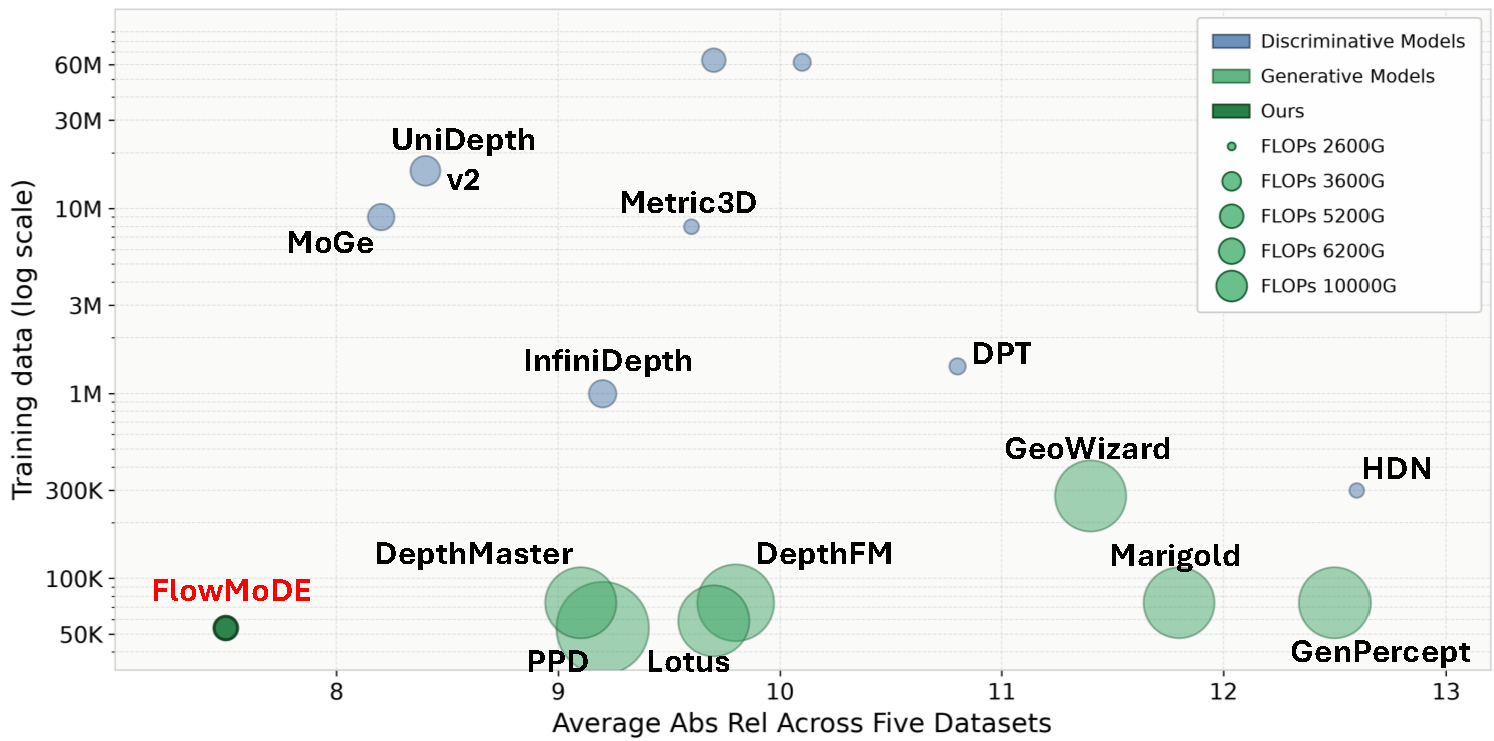
Quantitative Comparison with Existing Methods.
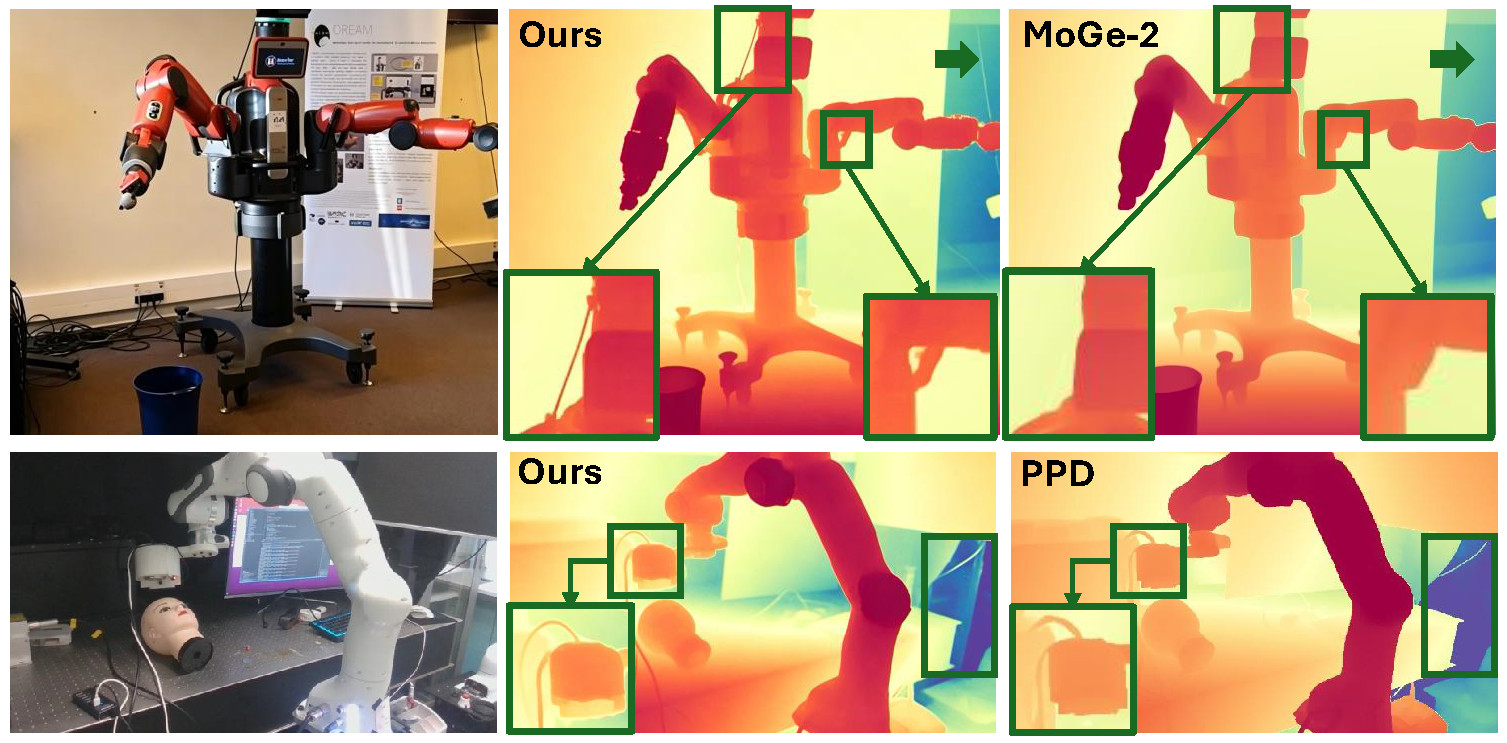
Qualitative Comparison with Existing Methods.
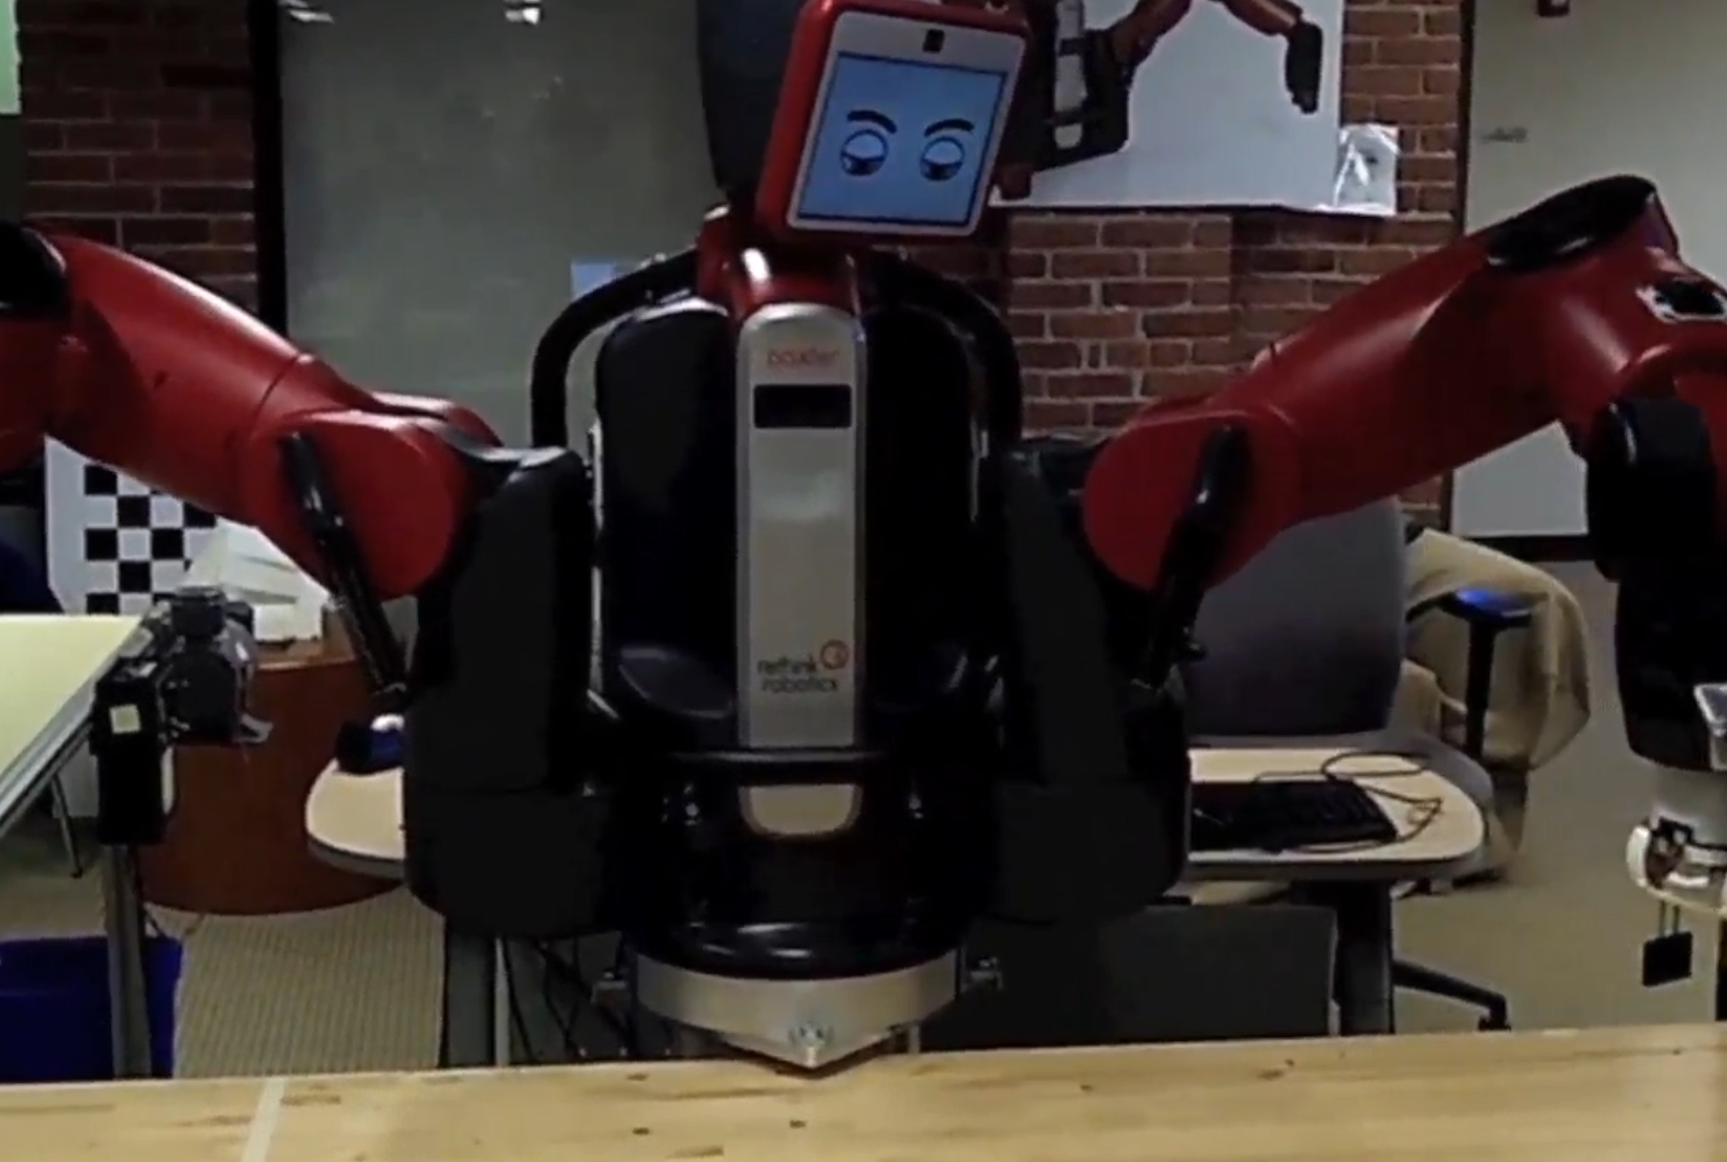
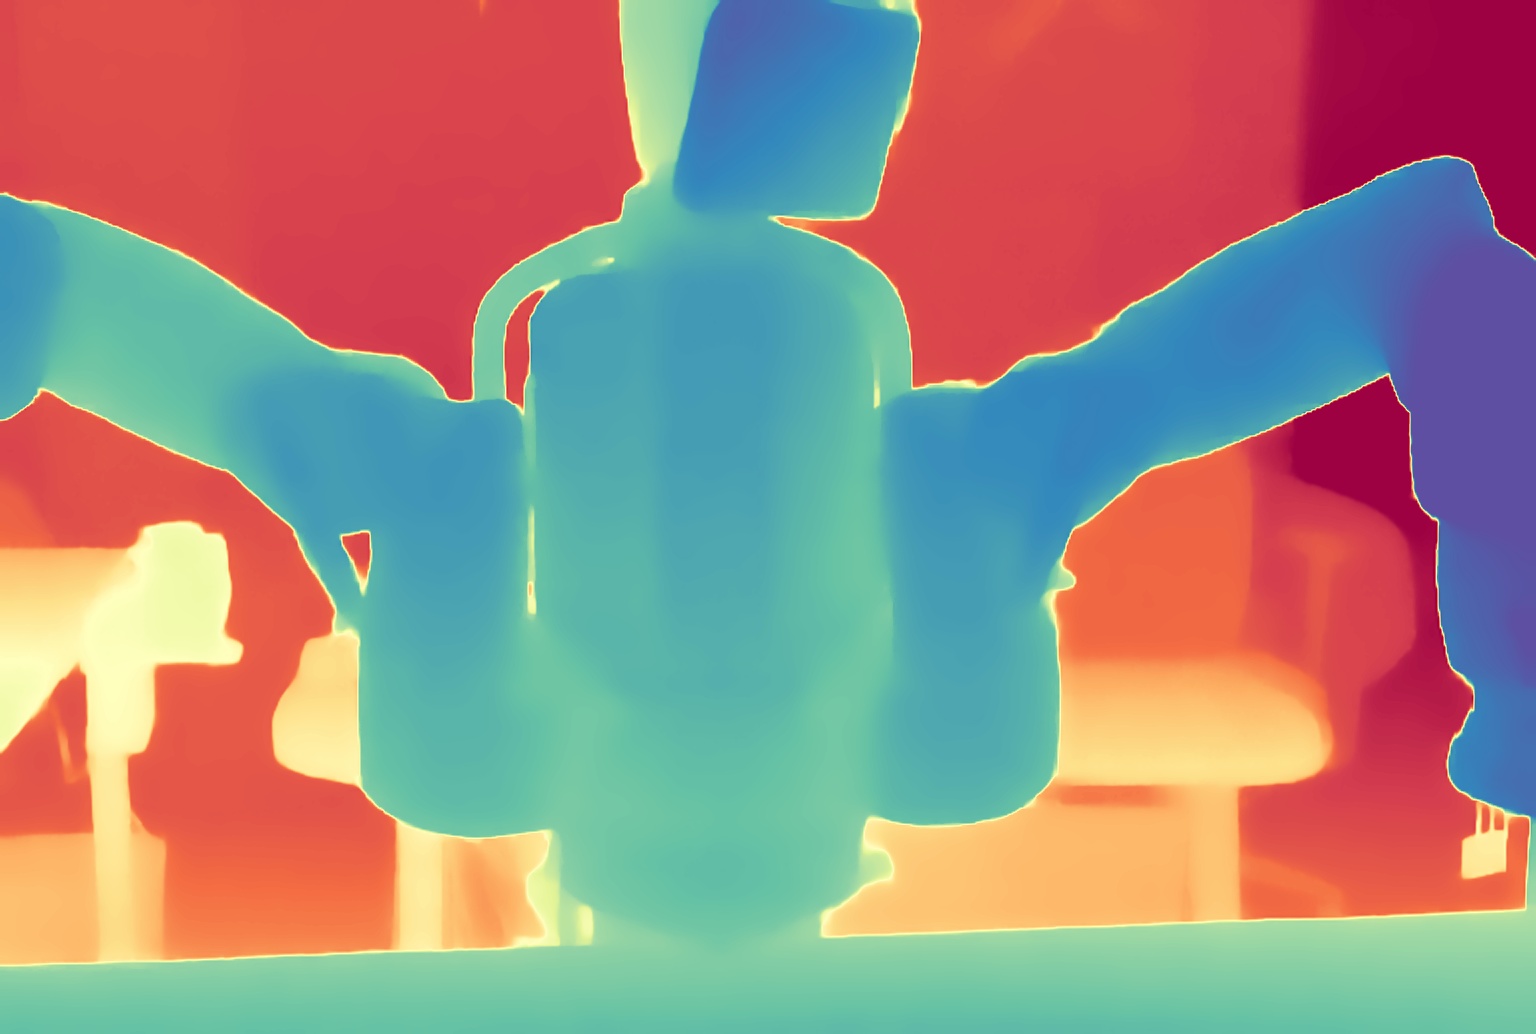
Qualitative Comparison on Robotic Scene with Baxter
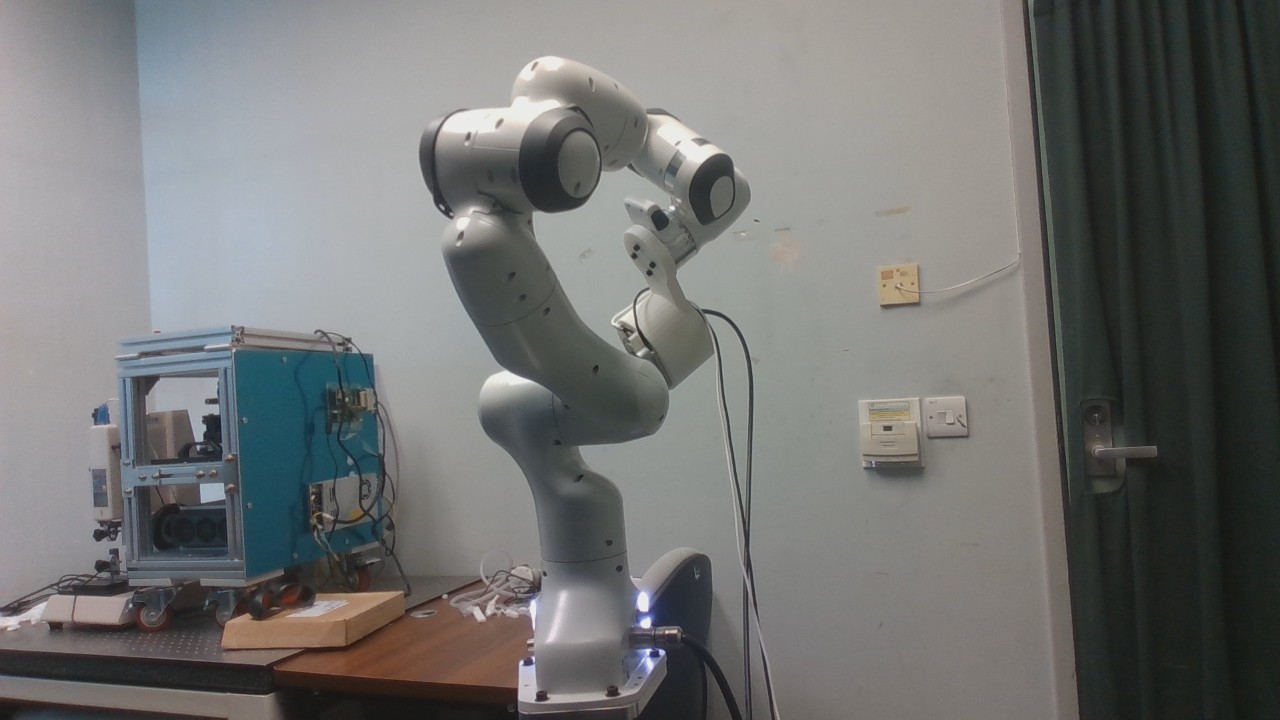
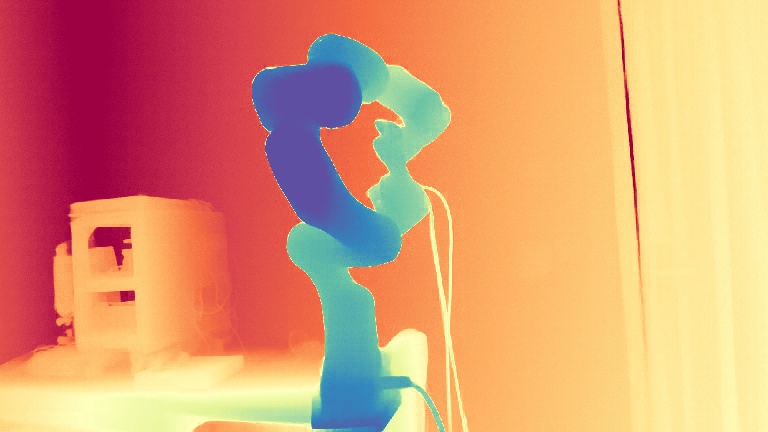
Qualitative Comparison on Robotic Scene with Franka
BibTeX
@article{shao2026flowmode,
  title={FlowMoDE: Coarse-to-fine Flow Matching for Structure-aware Sim-to-Real Monocular Depth Estimation},
  author={Liangjing Shao and Wanhao Liu and Jinsong Lin and Zhiwei Fang and Hongliang Ren},
  journal={Submitting},
  year={2026},
  url={coming soon}
}